DWG NO. JQ-2026-001  ·  SHEET 1 OF 1

Jack
Qiu

Prototype engineer. I take ideas from napkin sketch to working hardware to shipped software — and I own every layer in between: CAD, 3D printing, PCBs, firmware, servers, apps.

§1 SITE WORK — ARCHITECTURE

Buildings are prototypes too — spaces designed and built by hand, at 1:1 scale.

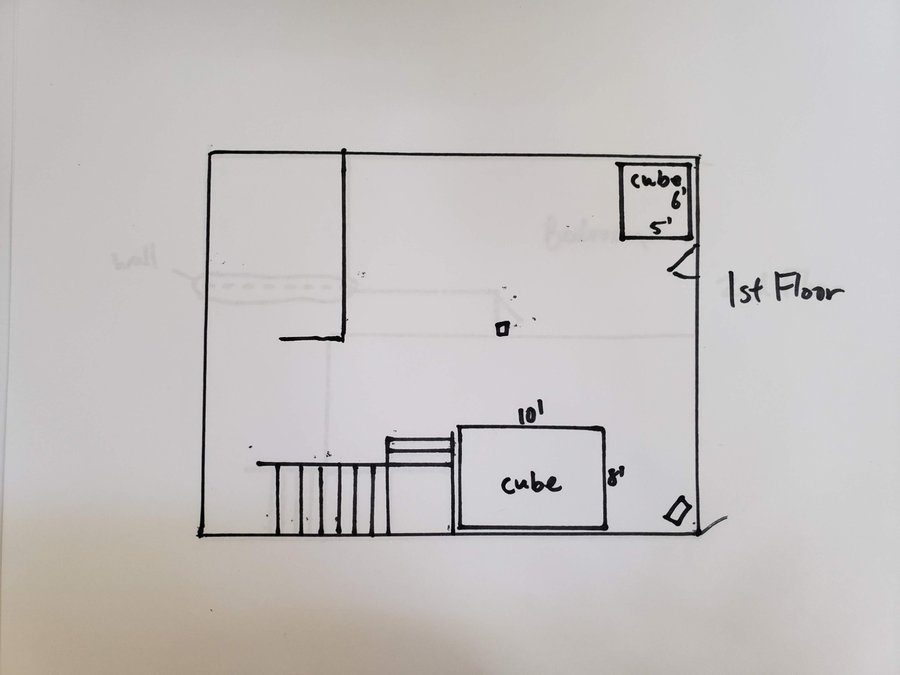
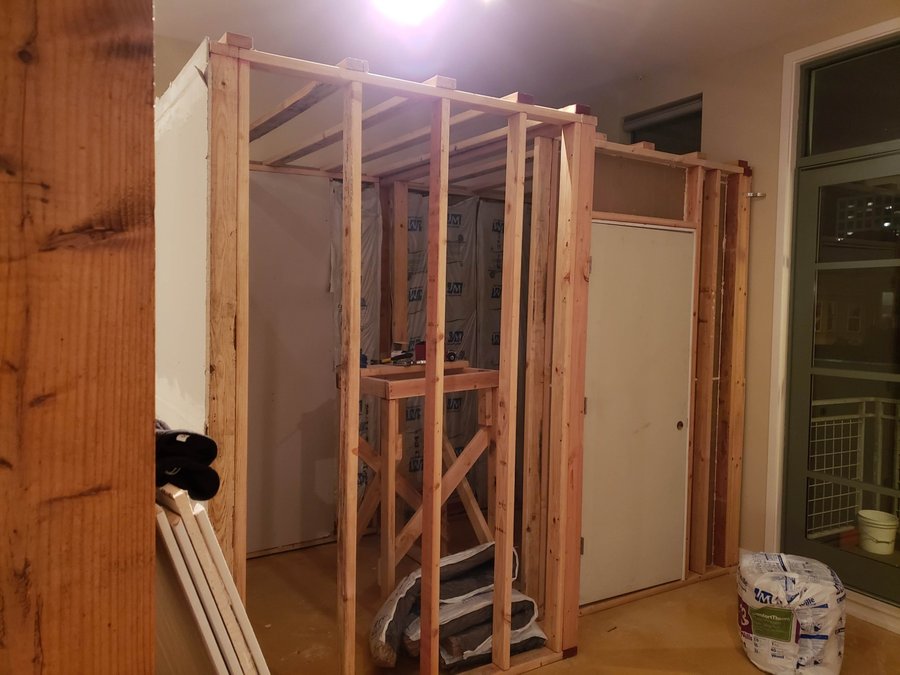
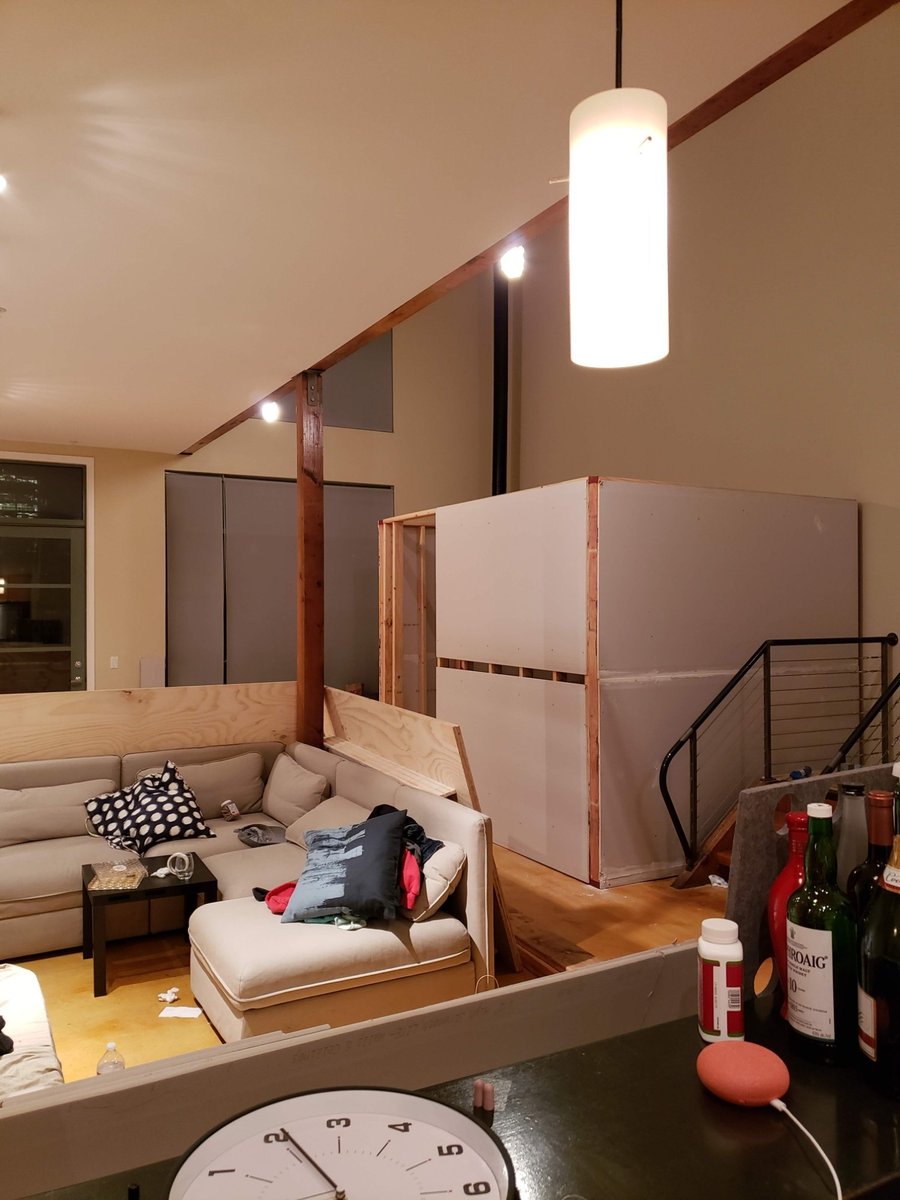
Hand-drawn first-floor plan showing two cube rooms, 10 by 8 feet and 6 by 5 feet Stud framing of the cube rooms going up inside the loft, with insulation staged Drywalled cube room taking shape beside the loft stairs View from above: painted roof deck on the cube with a lumber desk being framed on top
FIG. 1 — 81 LANGTON LOFTS, ROOM ADDITION. Two free-standing rooms (10′×8′ and 6′×5′) designed and built into an occupied SoMa loft: hand-drawn plan → stud framing & insulation → drywall → a painted roof deck with a built-in desk going up on top.
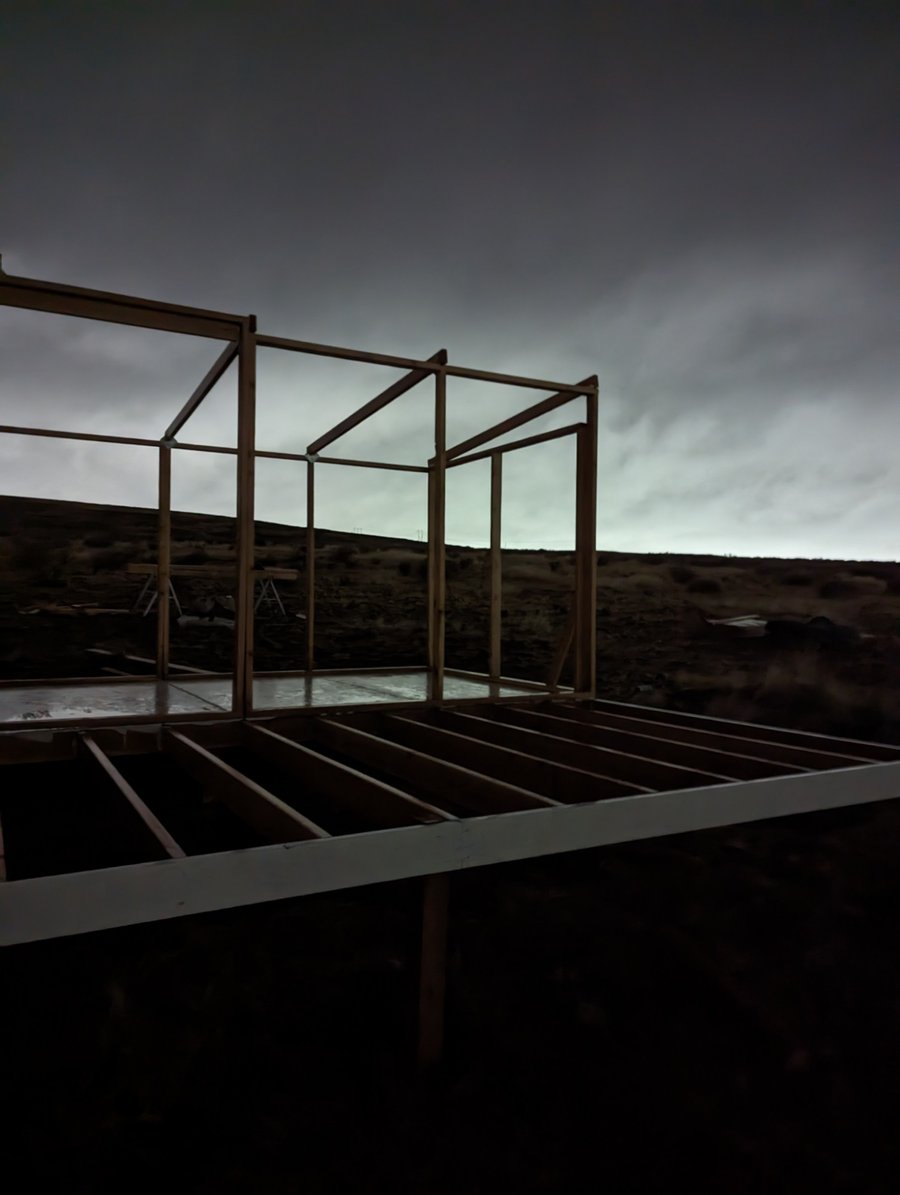
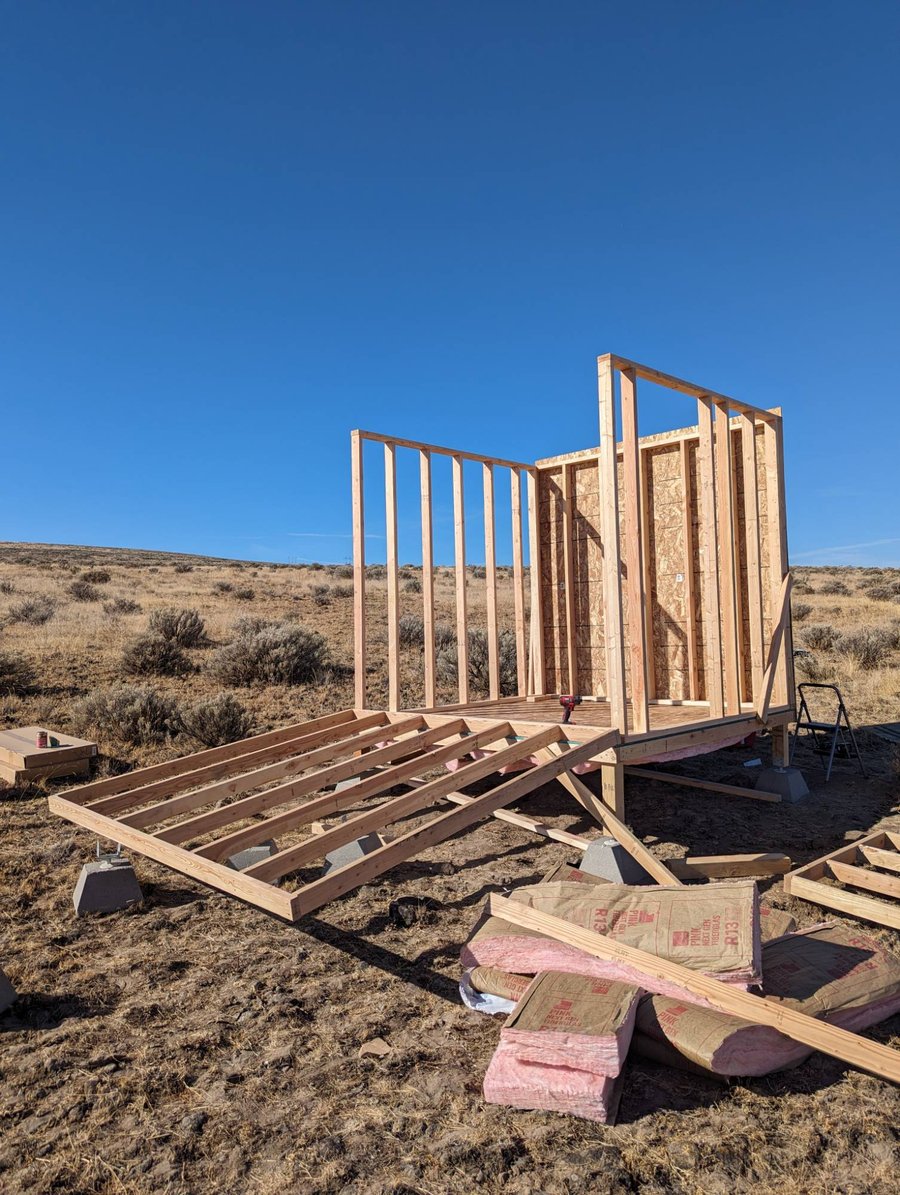
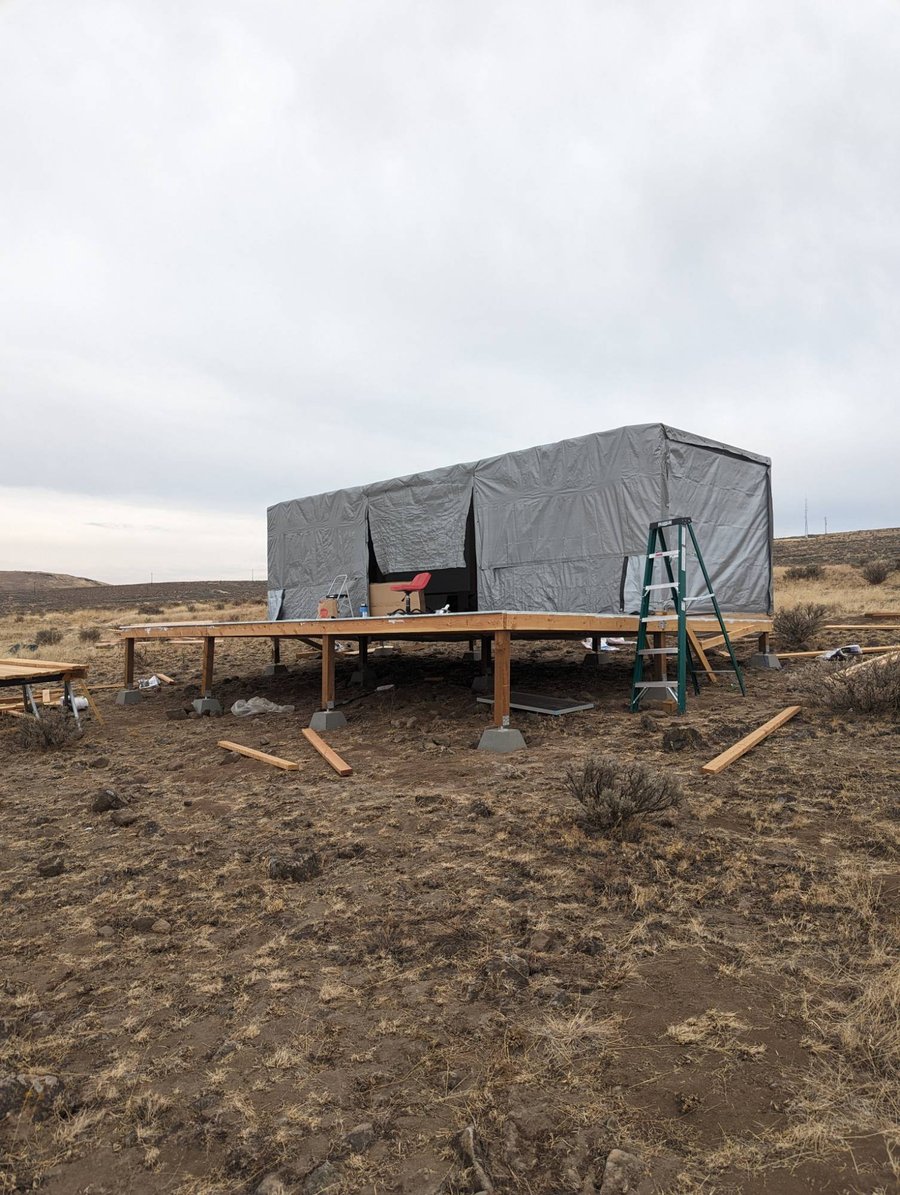
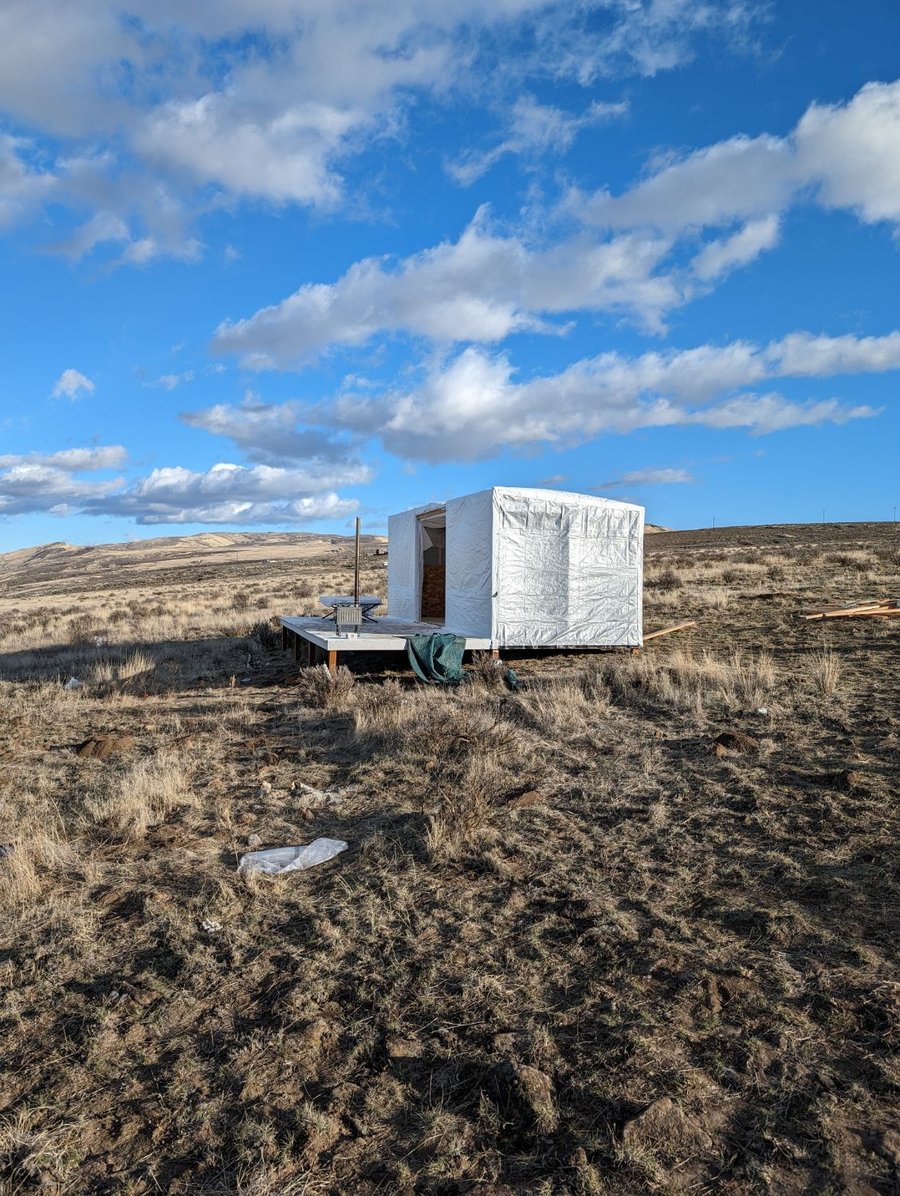
Bare timber frame on a raised platform against a stormy dusk sky on the sagebrush steppe Framed and sheathed walls going up on pier blocks, with insulation staged in the foreground The structure tarped weathertight on its raised platform, workspace inside The wrapped homestead structure standing alone under a blue sky in Yakima
FIG. 2 — YAKIMA HOMESTEAD. An off-grid, solar-powered homestead build on Washington's sagebrush steppe: pier-block foundation and raised platform, stick-framed and sheathed walls, insulated and wrapped weathertight — built from the ground up, far from the nearest outlet.
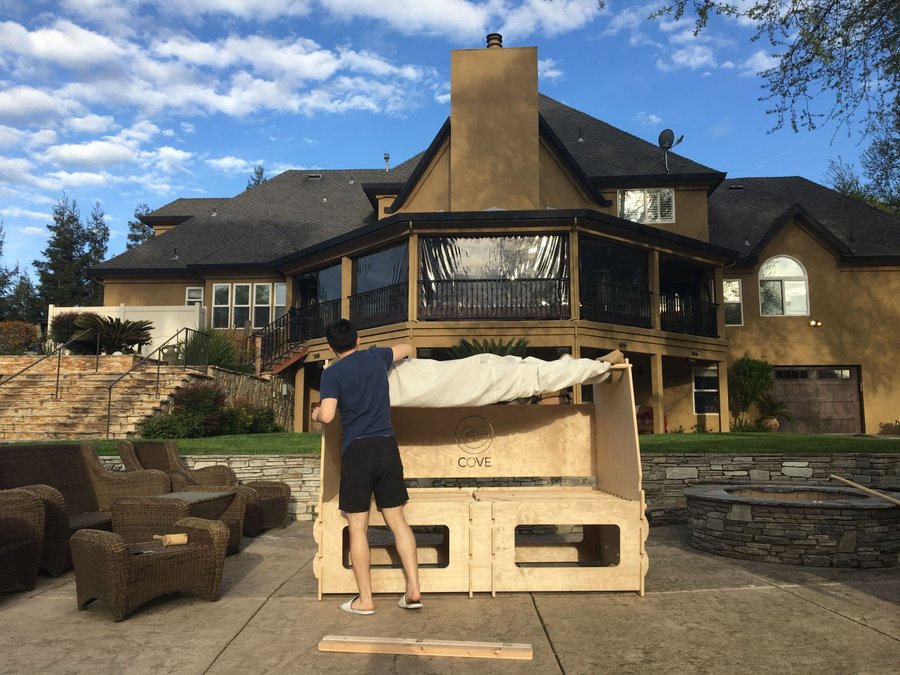
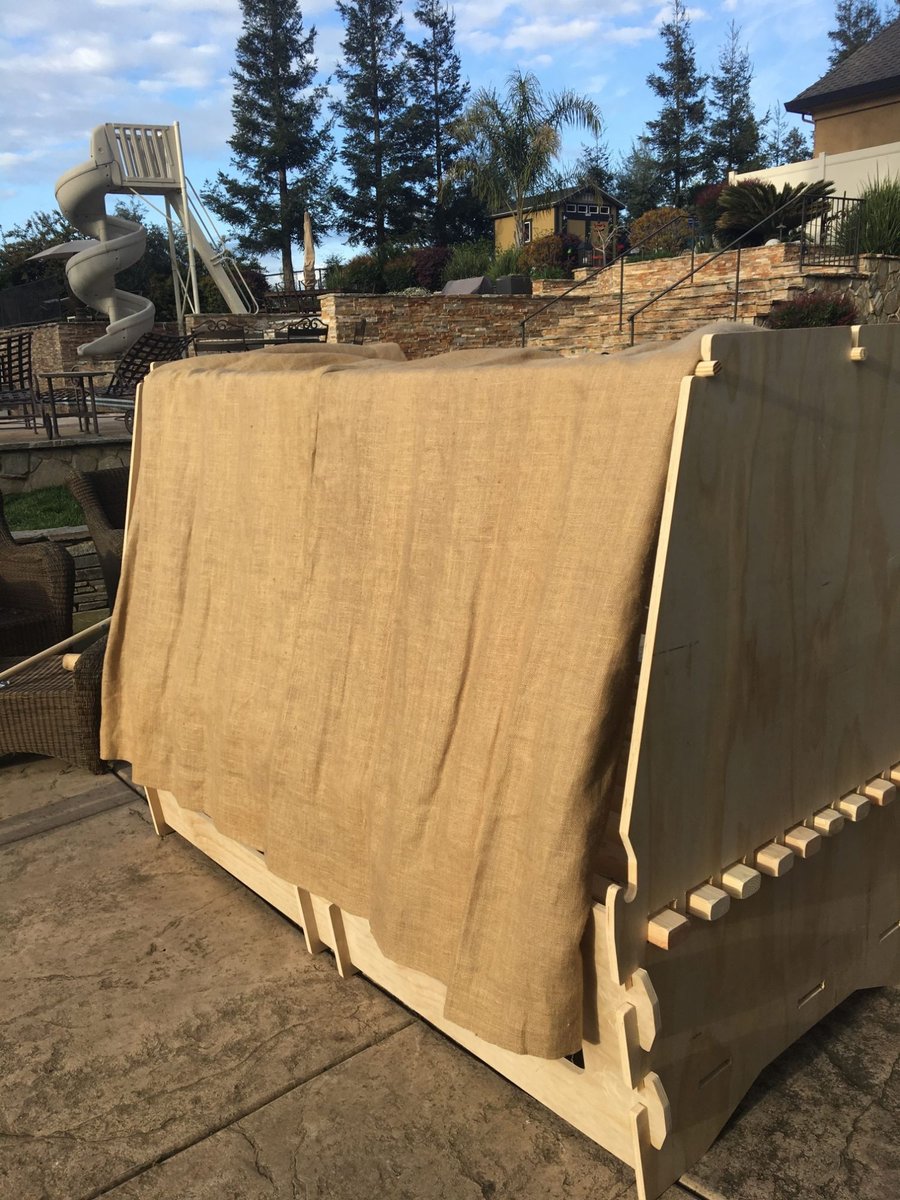
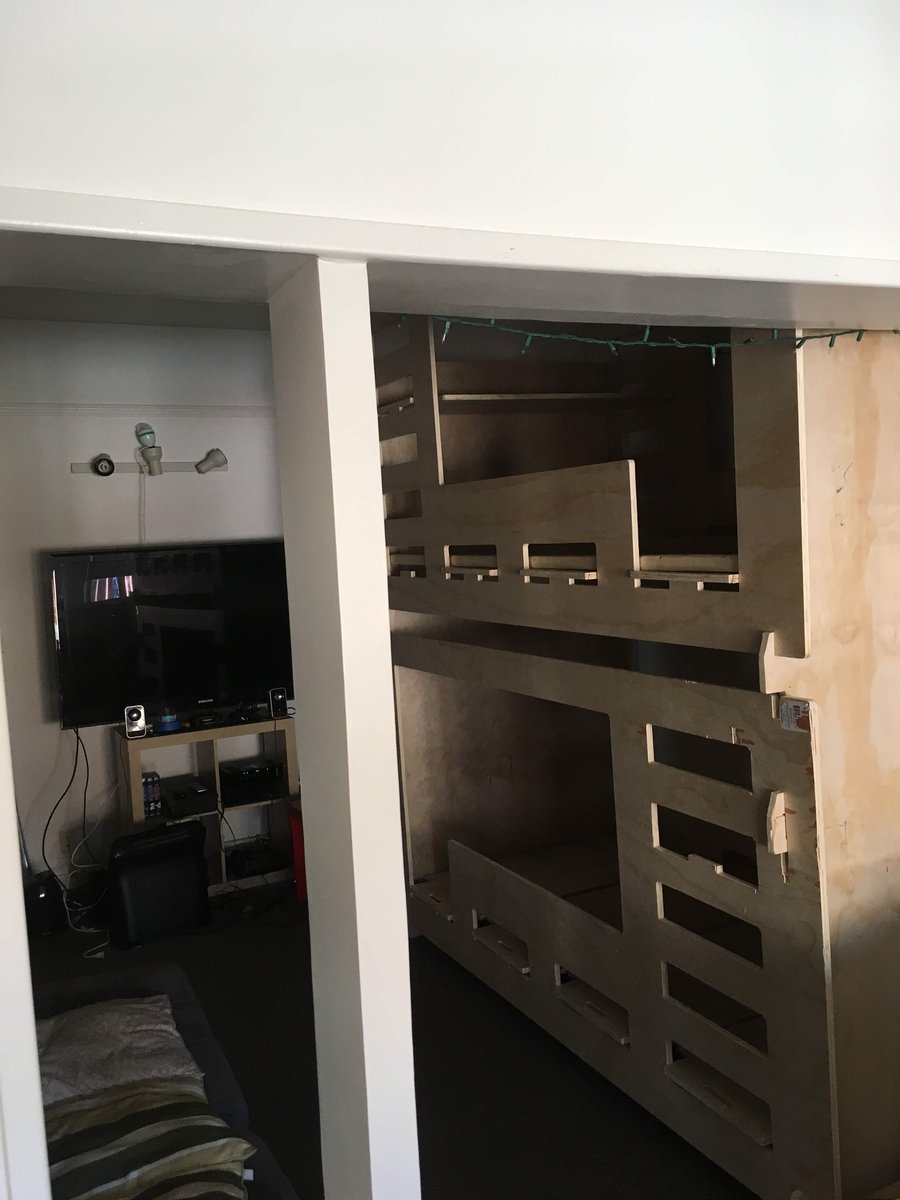
Assembling a flat-pack CNC-cut plywood COVE bed pod outdoors COVE bed pod with a burlap privacy canopy, showing wedge-and-peg joinery COVE bunk beds installed in a living room
FIG. 3 — COVE, LIVING-ROOM HOSTEL FURNITURE. Flat-pack, CNC-cut plywood bed pods that let hosts offer guests real beds — and real privacy — in living-room space. Slot-and-wedge joinery assembles in place with no fasteners; stacking bunks, privacy panels, and a canopy.
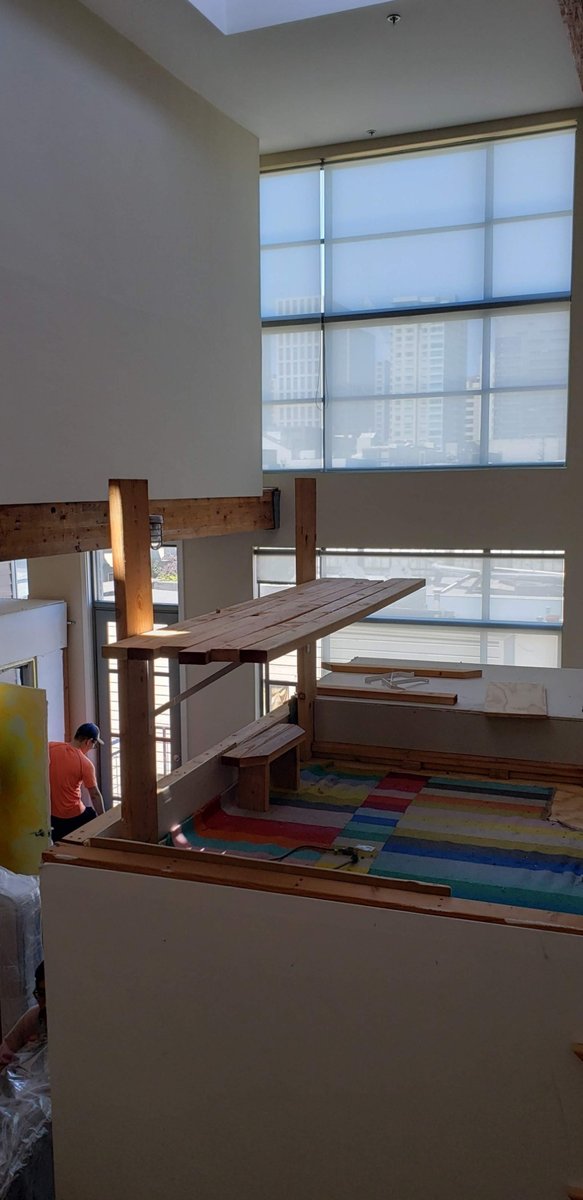
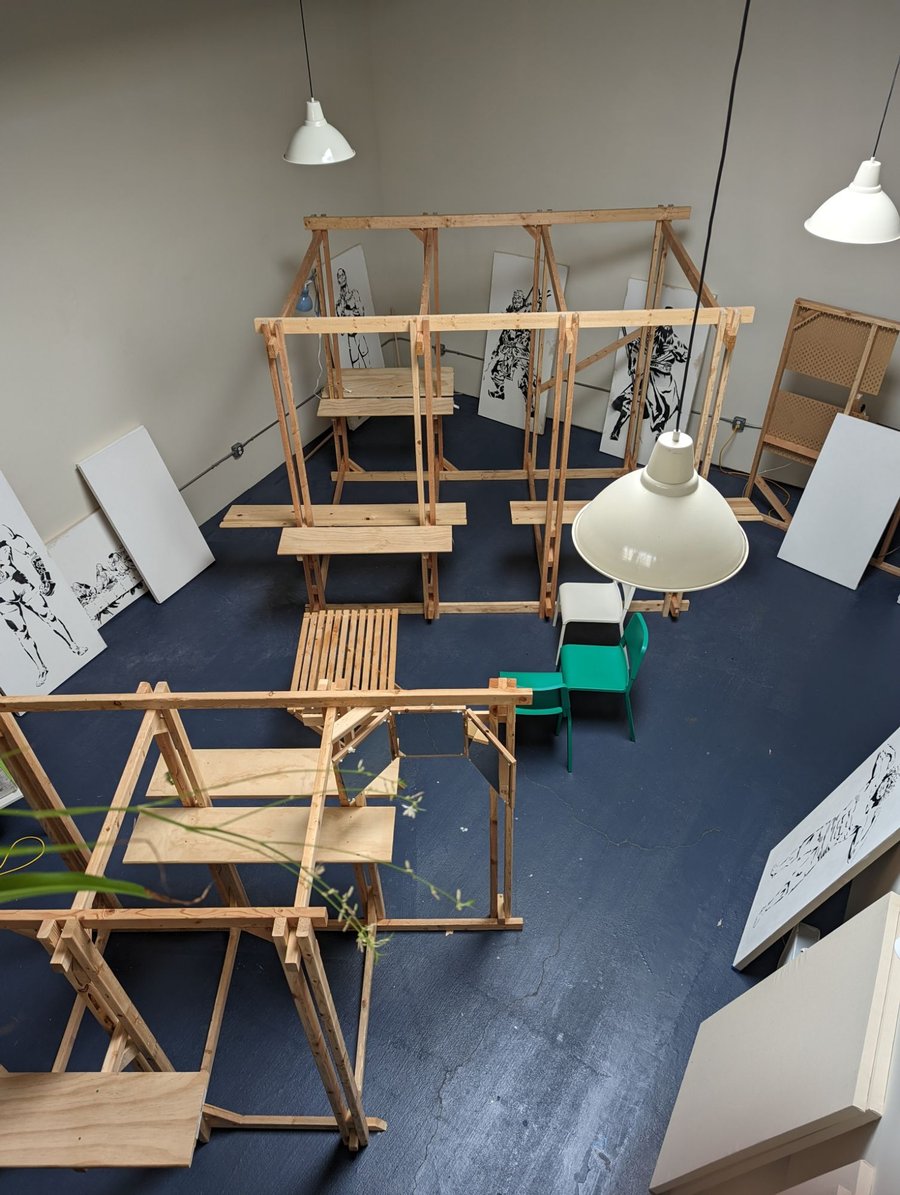
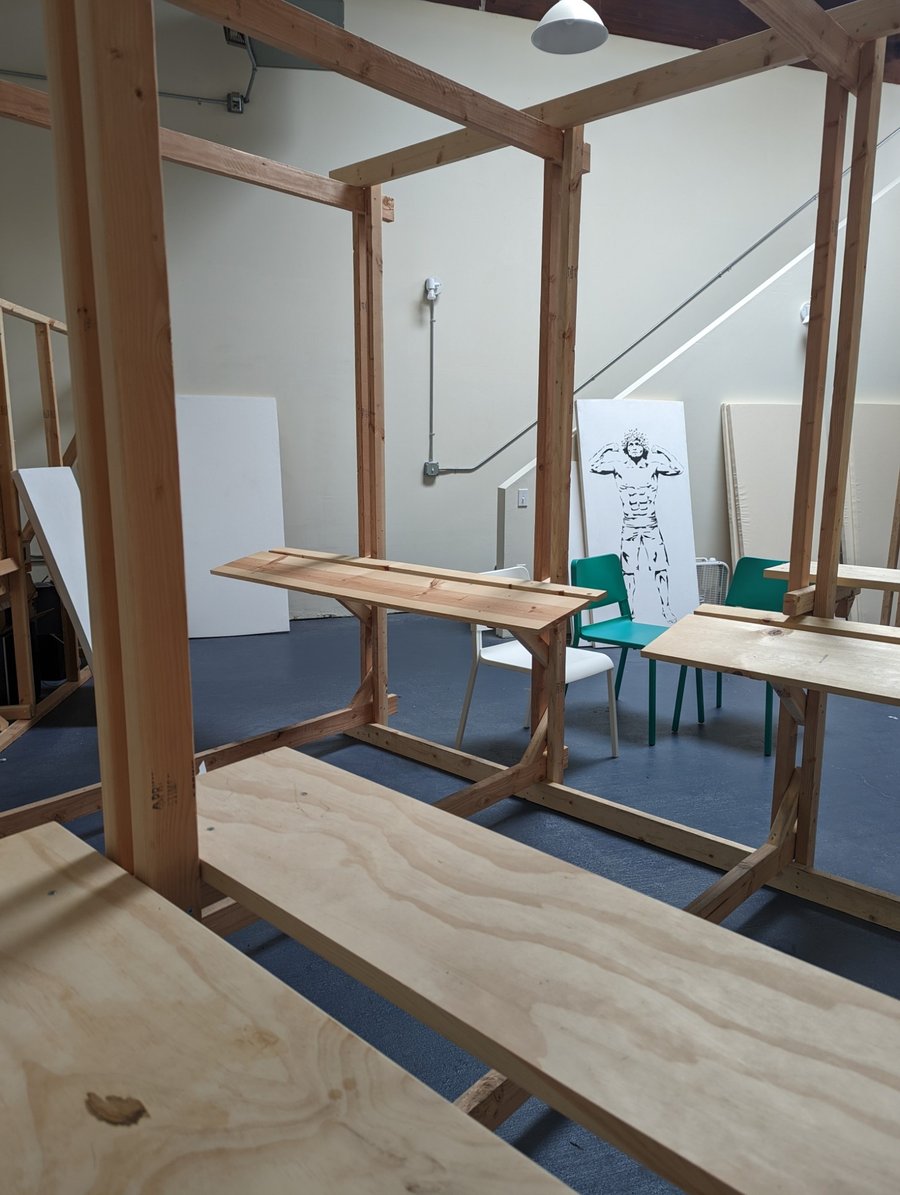
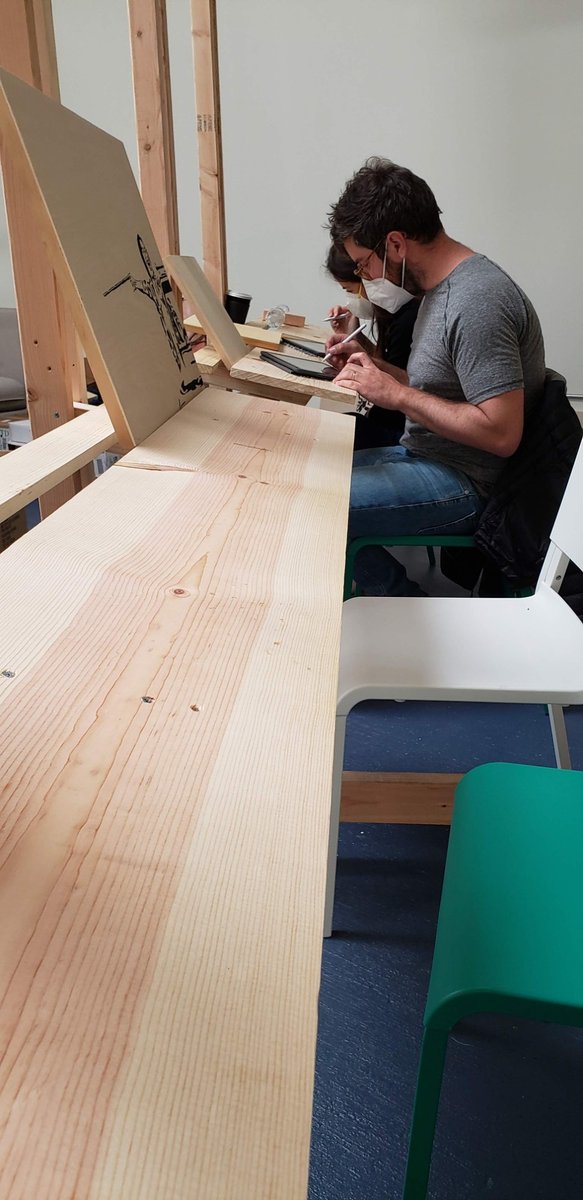
Overhead view of a studio with hand-framed timber painting stations, benches, and stencil paintings on display Timber painting station detail: bench seating with easel rails and work surfaces Guests painting stencils side by side at the bench during class
FIG. 4 — STENCIL PAINTING CLASS, STUDIO BUILD. Interior design for a stencil-painting class hosted on Airbnb Experiences: hand-framed timber painting stations with bench seating, easel rails, and display walls — a seating area purpose-built so guests can paint side by side.

§2 THE LOOP

  1. Sketch
  2. CAD
  3. Print
  4. Wire
  5. Firmware
  6. Server
  7. App
  8. Ship

Most people hand off between steps 3 and 5. I don't — that's the whole point. One person who can run the full loop prototypes in days, not quarters.

§3 SELECTED BUILDS

terrE

Telepresence rover, driven from anywhere

A four-wheel rover you drive from a web app in real time. Raspberry Pi onboard, PCA9685 PWM controller over I²C driving four continuous-rotation servos at 50 Hz, with a Socket.IO link to a Node server and a React control app. Per-wheel throttle thresholds, threaded drive loop, auto-stop watchdog.

MECH
4-wheel chassis, servo drive
ELEC
Raspberry Pi · PCA9685 · I²C @ 50 Hz PWM
FW
Python, threaded control loop
SW
Socket.IO · Node server · React teleop app
source ↗
FIG. 5 — terrE FIELD TEST. LIVE TELEOP OVER SOCKET.IO.

Duelists

Motion-sensing swords for live competition

Instrumented swords that stream 6-axis motion — MPU6050 accelerometer + gyro sampled at 100 Hz — from a Pi over Socket.IO into a live game server, with a custom PCB for the hardware and OBS overlays for the broadcast. Physical dueling, scored in software, streamed live.

MECH
Instrumented sword props
ELEC
MPU6050 IMU · custom PCB · I²C
FW
Python telemetry @ 100 Hz
SW
Realtime game server · stream overlays
source ↗
FIG. 6 — DUELISTS SWORD, BENCH TEST. 3D-PRINTED HILT, IMU INSIDE.

Mixellator Mask

UV air-disinfecting wearable, designed part-by-part in CAD

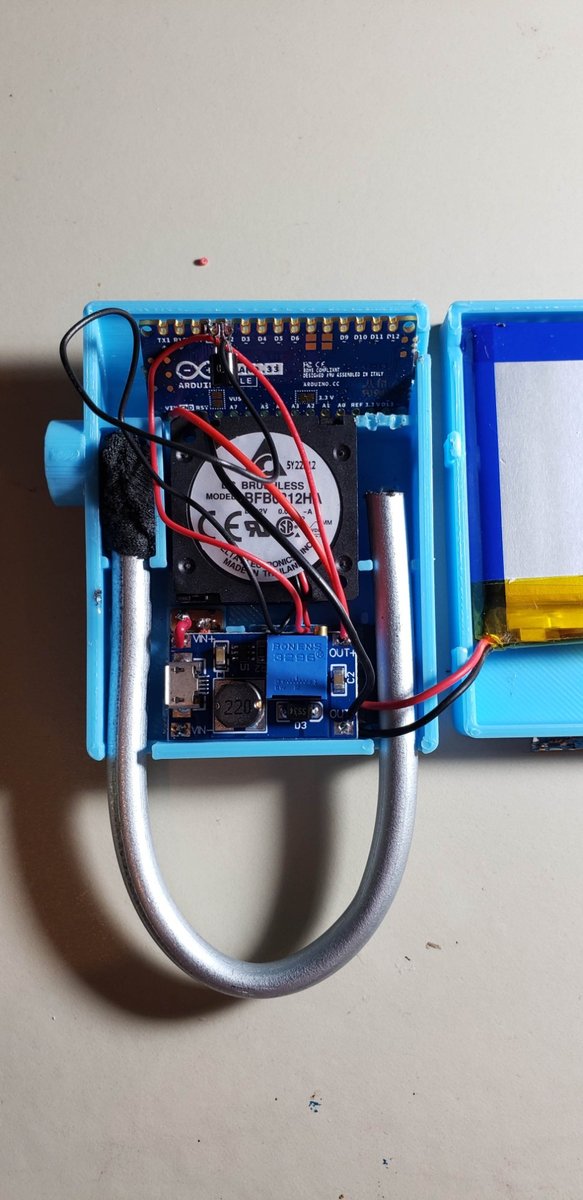
A COVID-era powered mask that actively treats airflow: a brushless blower drives air through a UV chamber before delivery. Engineered as a full SolidWorks assembly — intake chamber, exit chamber, top and bottom shells — 3D-printed from STLs, with Arduino Nano 33 BLE control and LiPo + boost-converter power inside.

MECH
SolidWorks assembly · 4-part shell · FDM print
ELEC
Arduino Nano 33 BLE · brushless blower · LiPo + boost converter
FW
C/C++
SW
—
source ↗
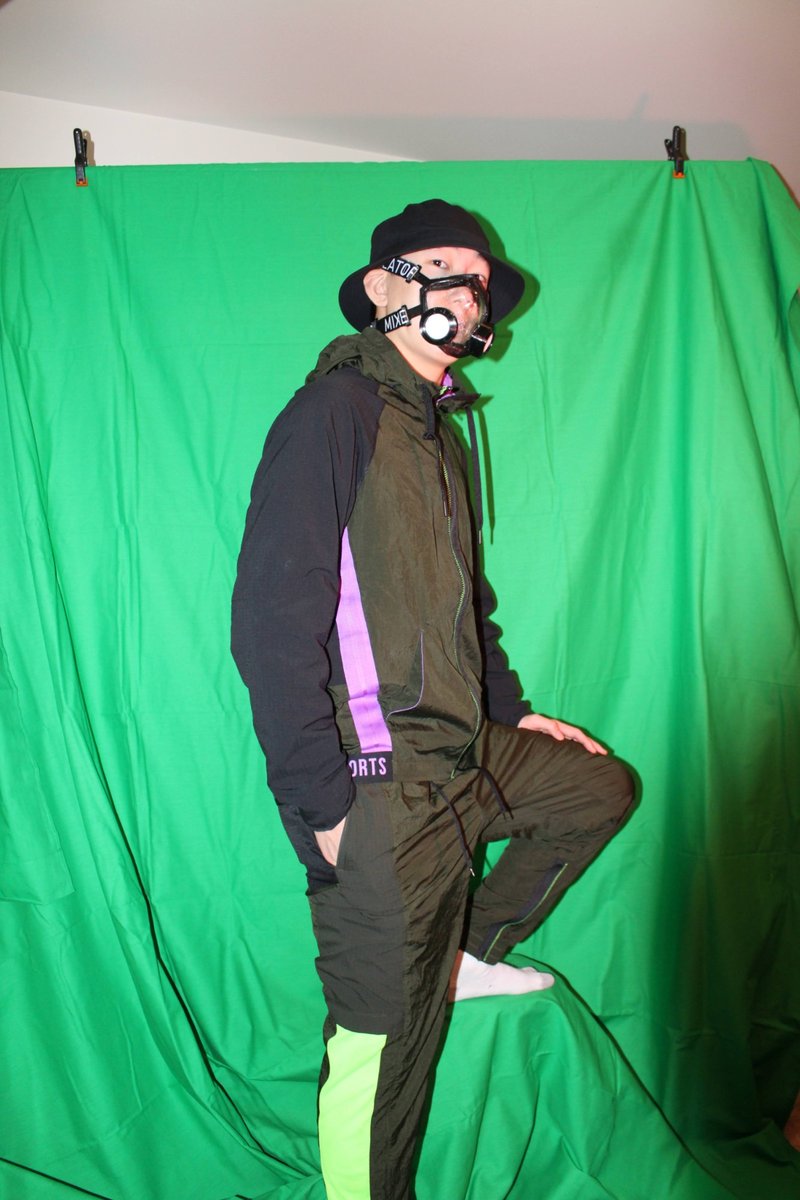
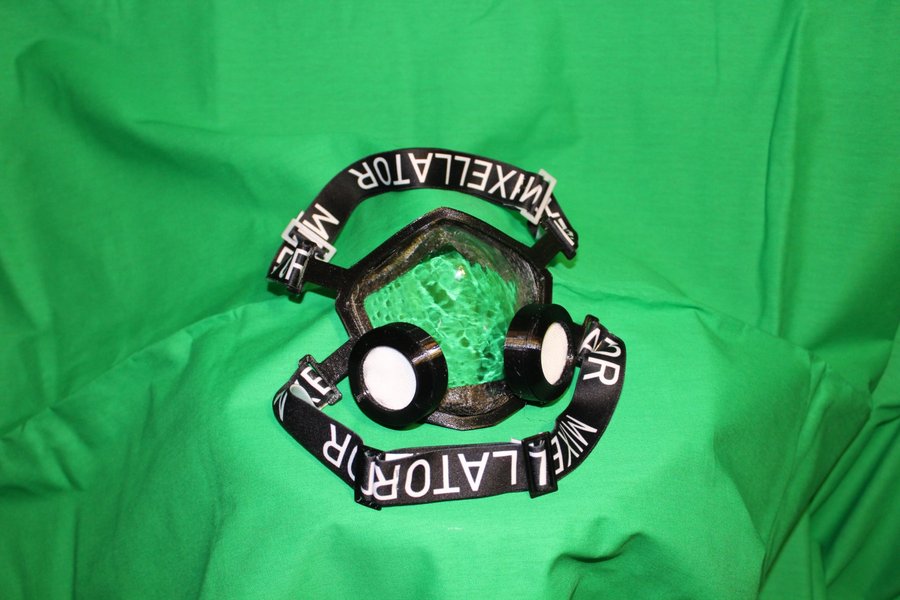
The Mixellator: a 3D-printed mask with twin filter pods and branded straps Mask electronics: Arduino Nano 33 BLE, brushless blower fan, boost converter, LiPo battery, and aluminum UV chamber tube Wearing the Mixellator mask in front of a green screen
FIG. 7 — MIXELLATOR AS BUILT: DEMO, SHELL, INTERNALS, WORN.

PixelVerse

A living pixel world run by AI agents

My current software venture: a persistent pixel world where autonomous AI agents live, build, and trade — Next.js on Vercel, Supabase, and an agent runtime with live dashboards for world activity, capacity, and cost. The same prototyping loop, applied to an entirely virtual machine.

MECH
—
ELEC
—
FW
—
SW
Next.js · Supabase · LLM agent runtime
thepixelverse.io ↗

§4 PRIOR ART — MECHANICAL

Before the robots: mechanical engineering work from Northwestern and industry. Full drawing set in the mechanical portfolio (PDF) ↗.

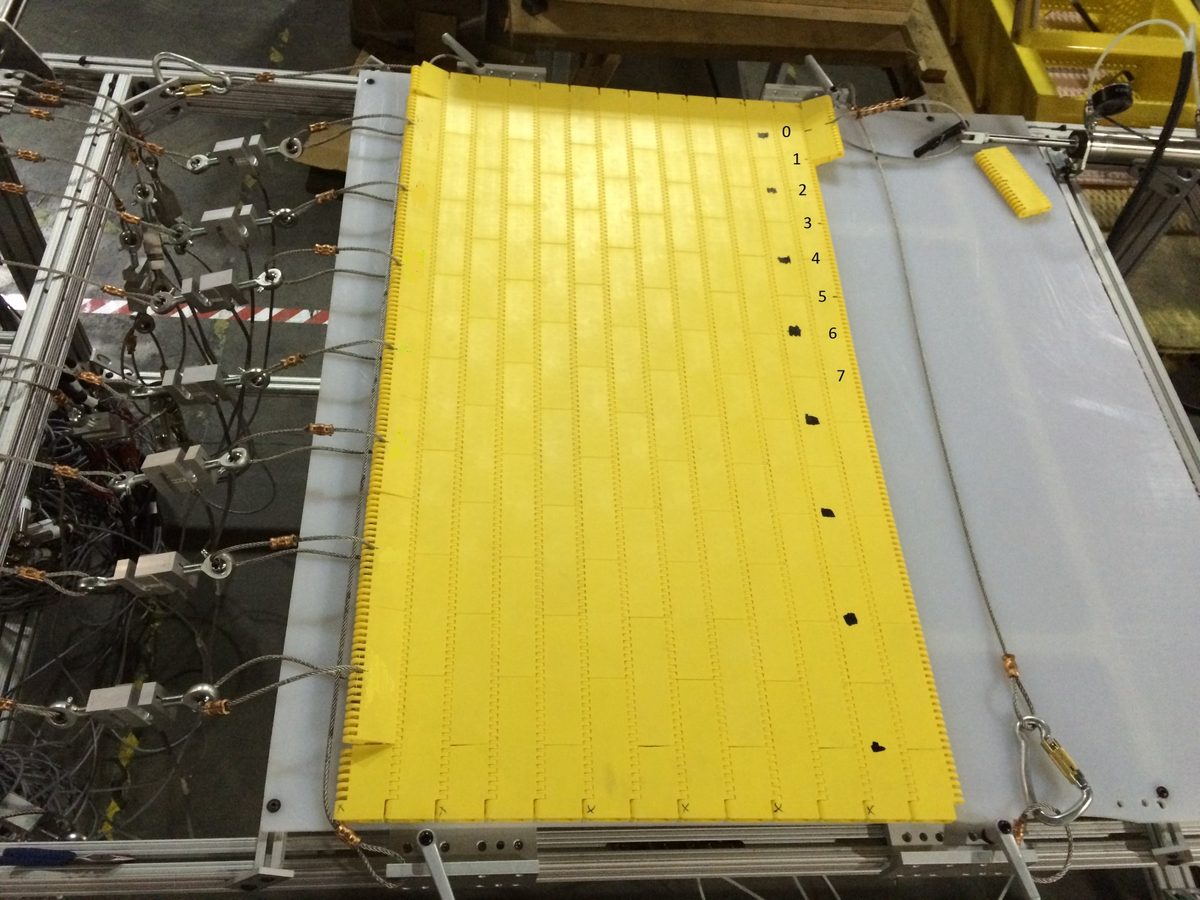
Test table with a yellow modular conveyor belt instrumented with load cells
FIG. 8 — LOAD DISTRIBUTION RIG. Piston + load-cell table measuring how concentrated loads spread across modular conveyor belts, with a Python model fitted to the measurements — motivated patched belts that extend fatigue life.
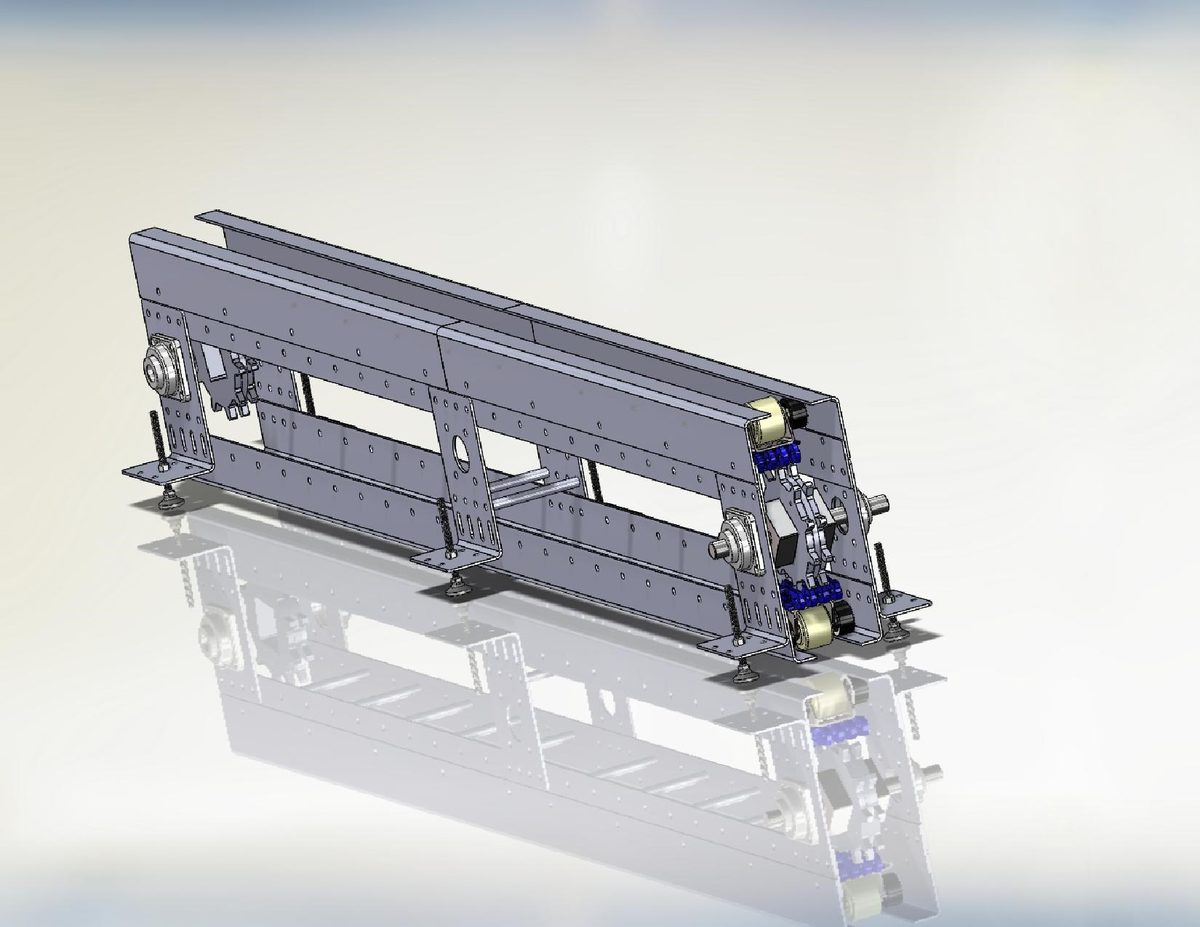
SolidWorks render of a sheet-metal accumulation conveyor frame
FIG. 9 — SKID CONVEYOR. All-sheet-metal accumulation conveyor for automotive paint-line skids: belt-mounted wheels double as moving catenary supports to fit a 0.5 m height limit. SolidWorks sheet-metal tools, two bolt sizes total, machined 304 SS drive shafts.
Machined aluminum and brass force-sensor fixture holding a glass plate
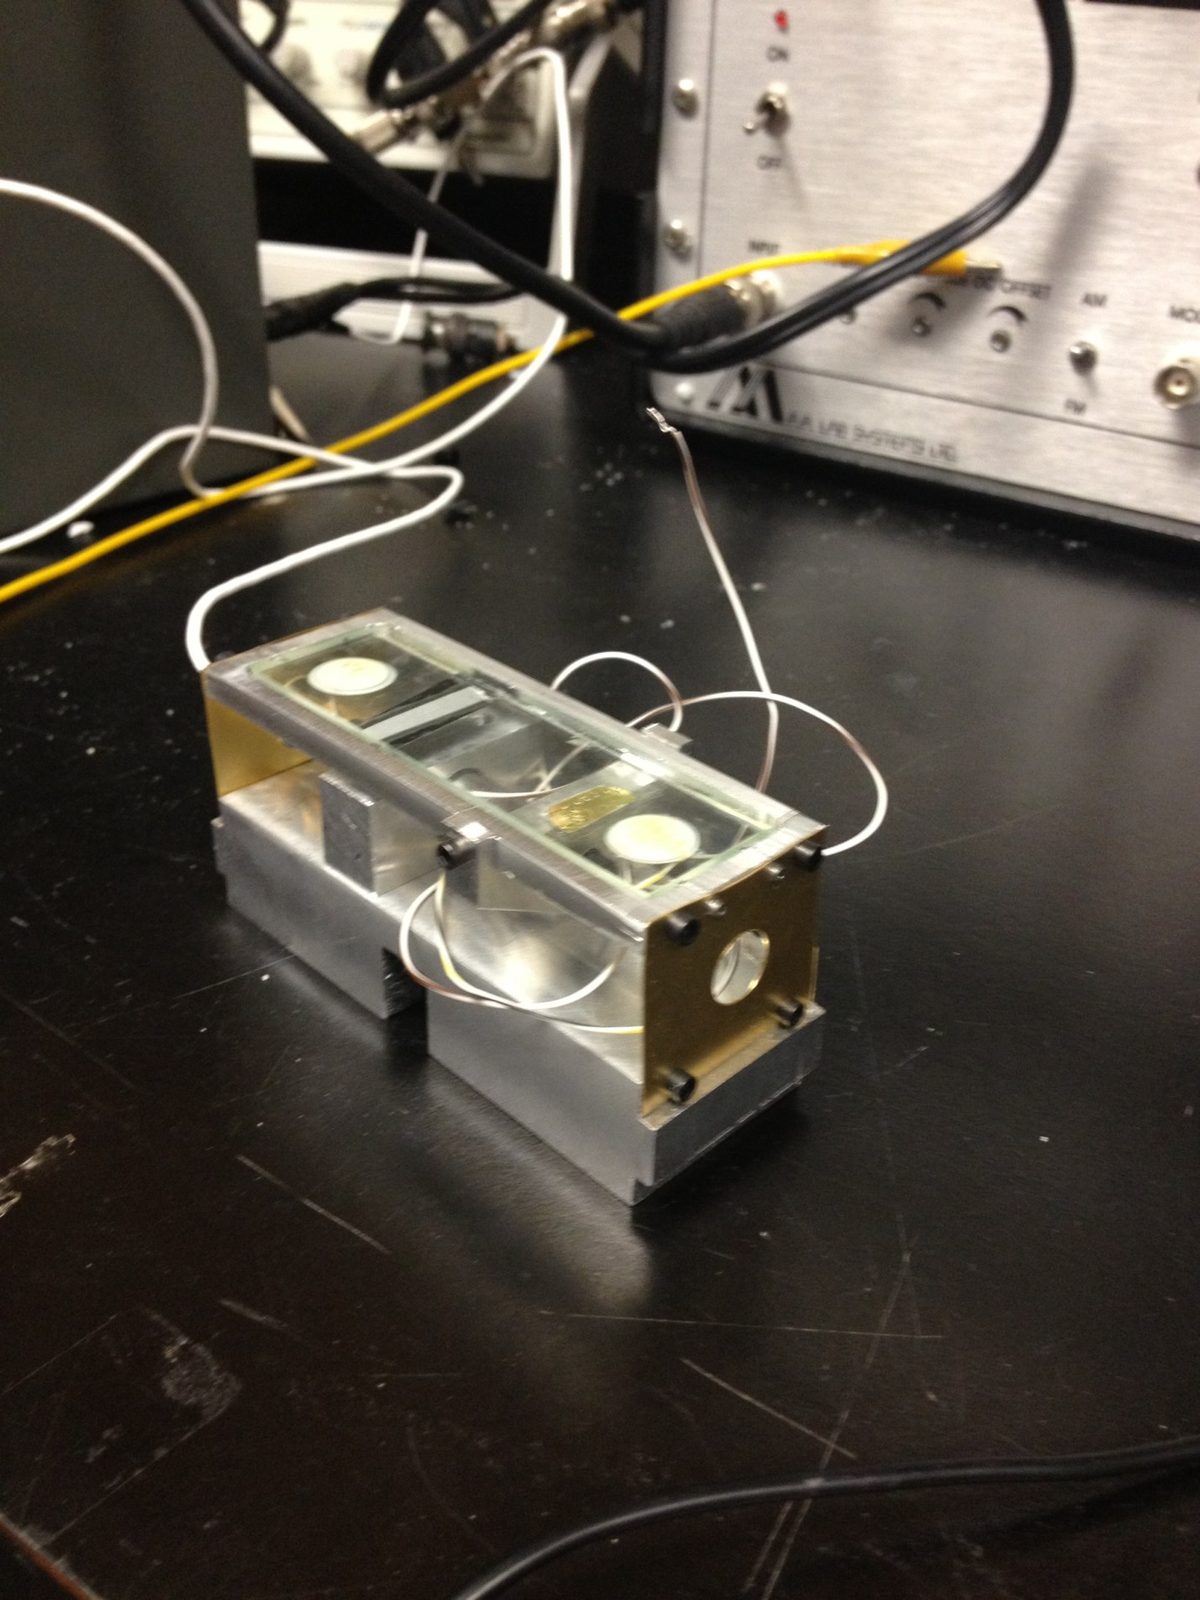
FIG. 10 — TPAD FORCE SENSOR. Machined aluminum-and-brass fixture measuring finger friction on ultrasonically vibrating glass (Northwestern NXR lab) — used in the experiments behind Dynamics of Ultrasonic and Electrostatic Friction Modulation.
Demonstrating the Cranken wall-mounted exercise apparatus with a resistance band
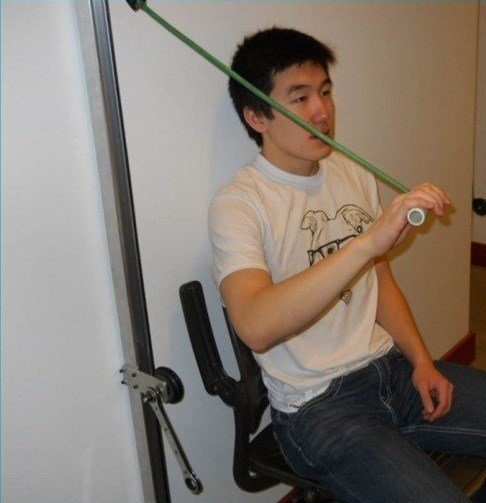
FIG. 11 — THE CRANKEN. Resistance trainer a wheelchair user with limited grip can operate entirely alone, via ratcheting levers driving a strut-encased pulley trolley. Best Design in category, Segal Design Institute 2013 Design Expo.
Exploded CAD view of a drafting pen with precision wheels
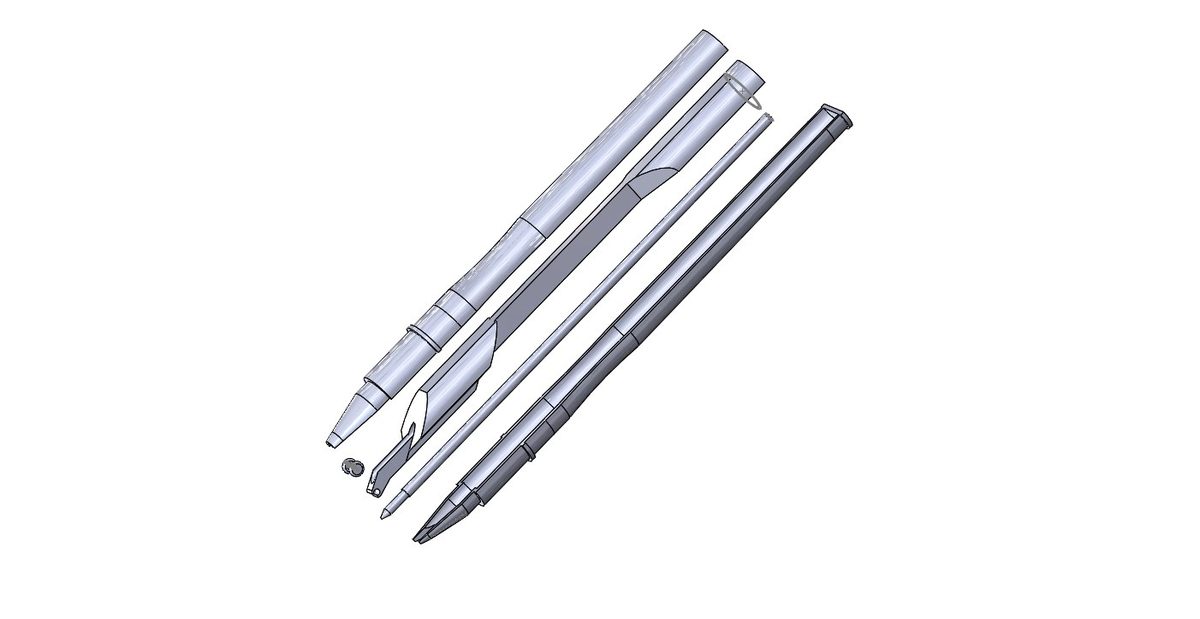
FIG. 12 — STRAIGHT. Drafting-pen concept that draws straight lines with no ruler: retractable precision wheels lock three contact points against the page.
Machined aluminum finger-tracking mechanism with encoder on a workbench
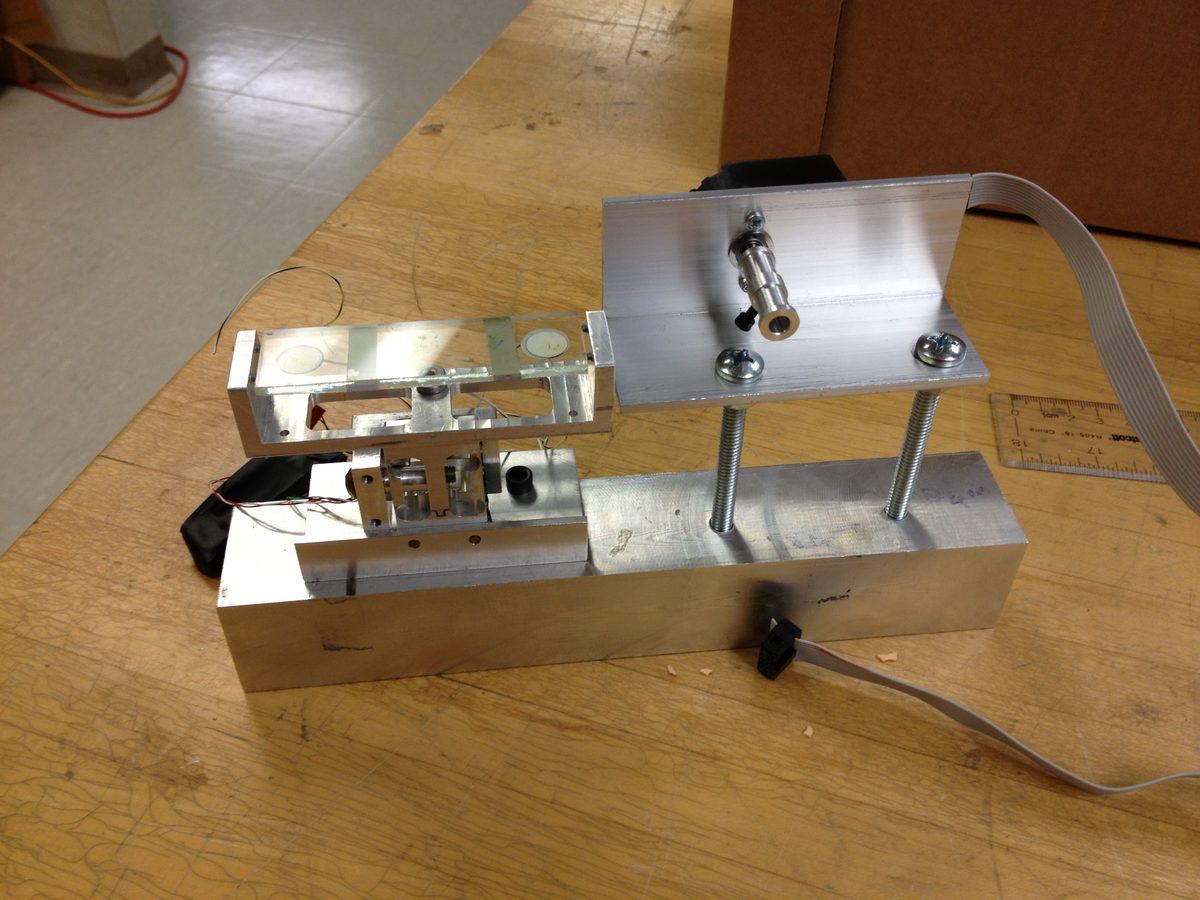
FIG. 13 — FINGER LOCATOR. 2 kHz finger-position tracker (encoder + DAQ, then laser-cut acrylic + steel cable) for rendering virtual textures — backed by a $5,000 McCormick grant and featured on Northwestern ME's flyer cover.

§5 BILL OF MATERIALS

ITEMDOMAINSPECQTY
01MechanicalSolidWorks (incl. sheet metal) · 3D printing (FDM) · machining (mill & lathe) · fits, tolerances & assemblies1 EA
02ElectricalPCB design · I²C / PWM / UART · IMUs, servos, load cells & DAQ1 EA
03FirmwarePython on Raspberry Pi · Arduino C/C++ · realtime control loops1 EA
04SoftwareJavaScript/TypeScript · React & Next.js · Node · Socket.IO · Supabase · Vercel1 EA
05AILLM agent systems · Claude API · autonomous agent worlds1 EA
06EducationNorthwestern mechanical engineering (McCormick) · UC Berkeley ML/AI professional certificate1 EA
07Day jobWoven by Toyota — software for the future of mobility1 EA

NOTE 1: ALL DOMAINS IN-HOUSE — NO HANDOFFS BETWEEN DISCIPLINES.